Begin with a controlled material flow
Engineering and machinery manufacturers may move raw materials, components, tooling, work-in-progress and finished assemblies between storage, machining, fabrication, inspection and assembly areas. AMRs can be evaluated for stable, repetitive movements when the load and handling interface are properly controlled.
The first opportunity should have defined pickup and delivery points, repeatable handling conditions and an operational objective that can be measured.
Potential engineering and machinery use cases
- Transfer of palletized components from storage to machining or assembly staging
- Movement of work-in-progress between controlled process areas
- Delivery of approved parts, tooling or load carriers to defined locations
- Transfer between inspection, buffer and production-support zones
- Return of empty pallets, stillages or reusable containers
- Finished-goods movement to warehouse or dispatch staging
These are application possibilities, not claims of completed WFC customer deployments. Every workflow requires verification of the site, load, carrier and interface.
Control load variation before selecting a vehicle
Engineering environments can involve components with different weights, footprints, centres of gravity and support requirements. Document the complete load range, carrier design, stability, fork-entry direction, pickup height, delivery height and required placement tolerance.
Where loads cannot be standardized on a suitable pallet, stillage or carrier, additional handling design may be required before an AMR workflow is practical. Payload capacity alone does not confirm suitability.
Match lift and transfer requirements
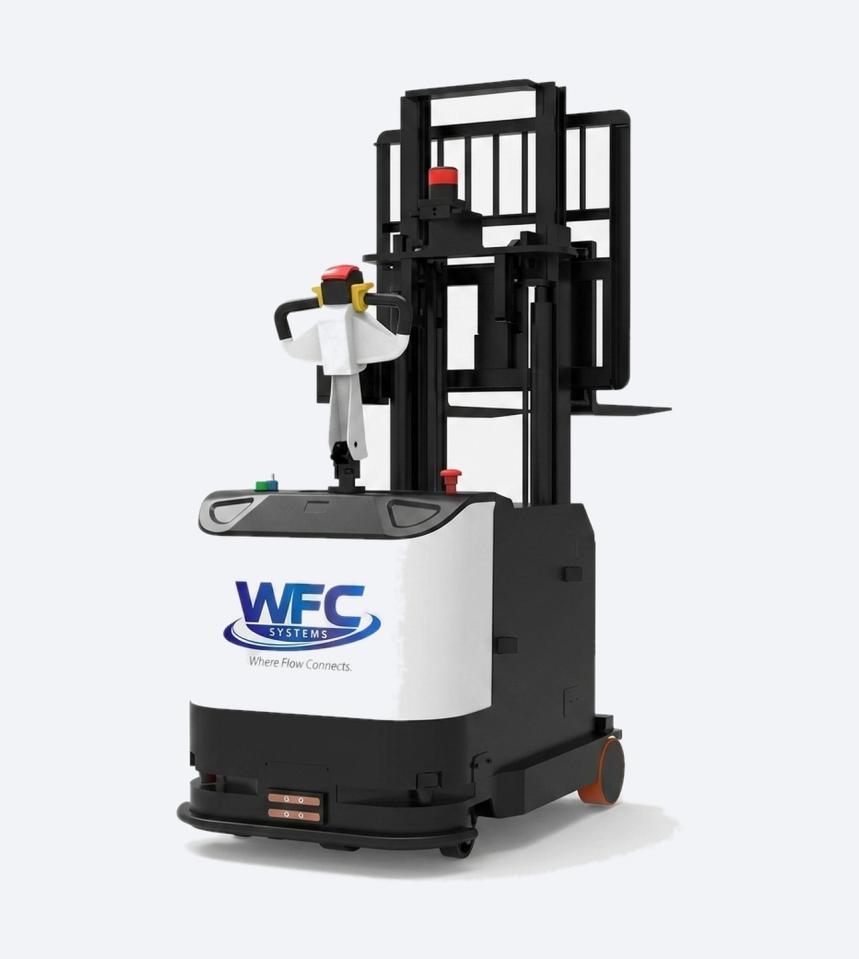
Floor-level pallet movement may point toward a pallet jack AMR. Elevated pickup, delivery or rack interaction may require evaluation of a reach truck AMR. The complete approach, clearance, carrier and transfer sequence must be verified.
Interfaces with machines, conveyors, racks, fixtures or operator stations should have controlled positions and an agreed confirmation method.
Assess the route during production
Measure usable aisle width, turning areas, doorways, crossings and staging space with the intended load included. Observe forklifts, cranes, trolleys, pedestrians, temporary work areas and material placed near routes during normal and peak operations.
Floors should be clean and suitable for the selected equipment. Metal chips, oil, dust, damaged surfaces, cables and uncontrolled obstructions may reduce suitability or require corrective controls.
Separate AMR movement from process hazards
Review heat, sparks, liquids, dust, suspended loads and other process-specific hazards along the proposed route. Do not assume standard equipment is suitable for a hazardous, contaminated or otherwise demanding environment. Required ratings and protections must be confirmed for the selected equipment and application.
Plan people, systems and exceptions
Define traffic rules, restricted areas, crossings, emergency access and responsibility for route availability. If production, warehouse or enterprise-system integration is required, document task creation, interface ownership, status feedback and exception handling before confirming scope.
Plan responses for a missing or unstable load, blocked route, unavailable station, dimensional variation or incomplete task. The selected solution requires project-specific risk assessment, validation and training.
Stronger project-readiness signals
- A repetitive movement with known volumes and timing
- Standardized, stable pallets, stillages or load carriers
- Controlled pickup and delivery interfaces
- Clean floors and sufficient route clearances
- An operations or engineering owner with decision-making authority
- A realistic budget and measurable pilot objective
- Coordination between operations, engineering, safety and IT where required
Build a pilot from verified operating data
Record current trip frequency, distance, operating windows, waiting time, manual interventions and process constraints. Use measured baseline information to define pilot acceptance criteria such as task completion, interface reliability and agreed exception response. Avoid generic productivity or return-on-investment assumptions.
A practical next step
WFC Systems can begin with an application discussion covering the load range, carrier, route, lift requirement, process environment, interfaces and intended outcome. Suitable opportunities can then progress to a site-readiness review and pilot-planning discussion.
Compare current WFC AMRs →
Use the site-readiness guide →
Plan a credible AMR pilot →